01
Autonomous Navigation Systems
ROS 2 navigation, mapping, localization, planning, controls and sensor integration for autonomous mobile robots.
Explore this service →
Engineering support for ROS 2, NVIDIA Omniverse and Physical AI—from digital twins, perception and robot learning to humanoids, quadrupeds, AMRs and industrial deployment.
Companies, research teams and publishers we have built robot software, training and books with.
From ROS 2 engineering to Physical AI, we help teams build, train, validate and deploy modern robot systems.
ROS 2 navigation, mapping, localization, planning, controls and sensor integration for autonomous mobile robots.
Explore this service →
Pick-and-place, bin picking, grasping, motion planning and force-aware manipulation for industrial robot arms.
Explore this service →
2D and 3D vision, LiDAR, depth cameras, detection, tracking and GPU-accelerated ROS 2 perception pipelines.
Explore this service →
Custom interfaces and drivers for cameras, LiDARs, motor controllers, embedded systems and complete robot platforms.
Explore this service →
OpenUSD digital twins, NVIDIA Omniverse, Isaac Sim, software-in-the-loop testing and synthetic data workflows.
Explore this service →
ROS 2 applications for humanoids: navigation, perception, manipulation, teleoperation and sim-to-real validation.
Explore this service →
Autonomous inspection, terrain-aware navigation, perception, payload integration and remote operator workflows.
Explore this service →
Reinforcement learning, imitation learning, demonstration data, policy evaluation and controlled deployment workflows.
Explore this service →
Vision-language models and vision-language-action prototypes for scene understanding, task planning and robot interaction.
Explore this service →
RTX sensor simulation, domain randomization, synthetic datasets, teleoperation data and Physical AI evaluation pipelines.
Explore this service →
Hands-on training in navigation, manipulation, perception, drivers, Docker, simulation and deployment.
Explore this service →
OpenUSD, Omniverse, Isaac Sim, Isaac ROS, Isaac Lab, digital twins, synthetic data and robot learning workshops.
Explore this service →Solution areas spanning humanoids, robot learning, navigation, manipulation and simulation.
Localization, navigation, obstacle awareness, safety boundaries and mission-level task control for humanoid platforms.
Explore this service →3D scene understanding, grasp planning and task execution with humanoid arms and dexterous end effectors.
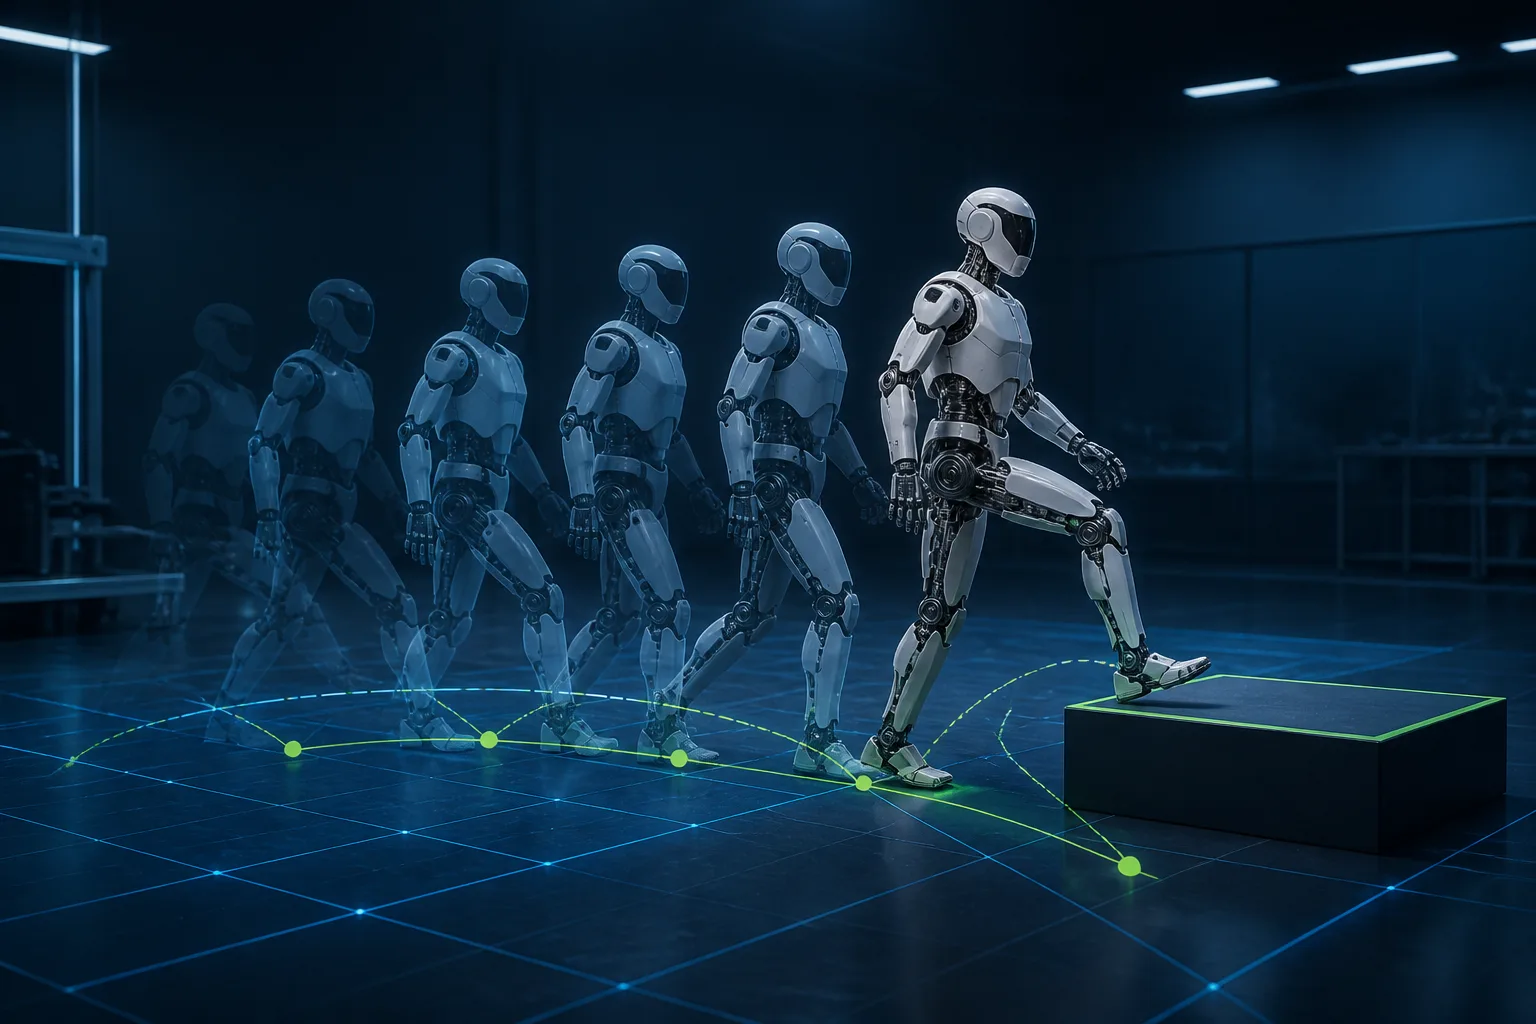
Simulation environments, reward design, policy training, evaluation and controlled sim-to-real transfer for humanoids.
Demonstration collection, dataset processing, policy training and deployment validation for embodied robot tasks.
Natural-language task interfaces, visual grounding, semantic scene understanding and controlled action pipelines.
Perception-led patrols, mapping, waypoint navigation and remote operator workflows for quadruped robots.
Warehouse simulation, sensor modelling, navigation stress testing and synthetic data generation for AMR systems.
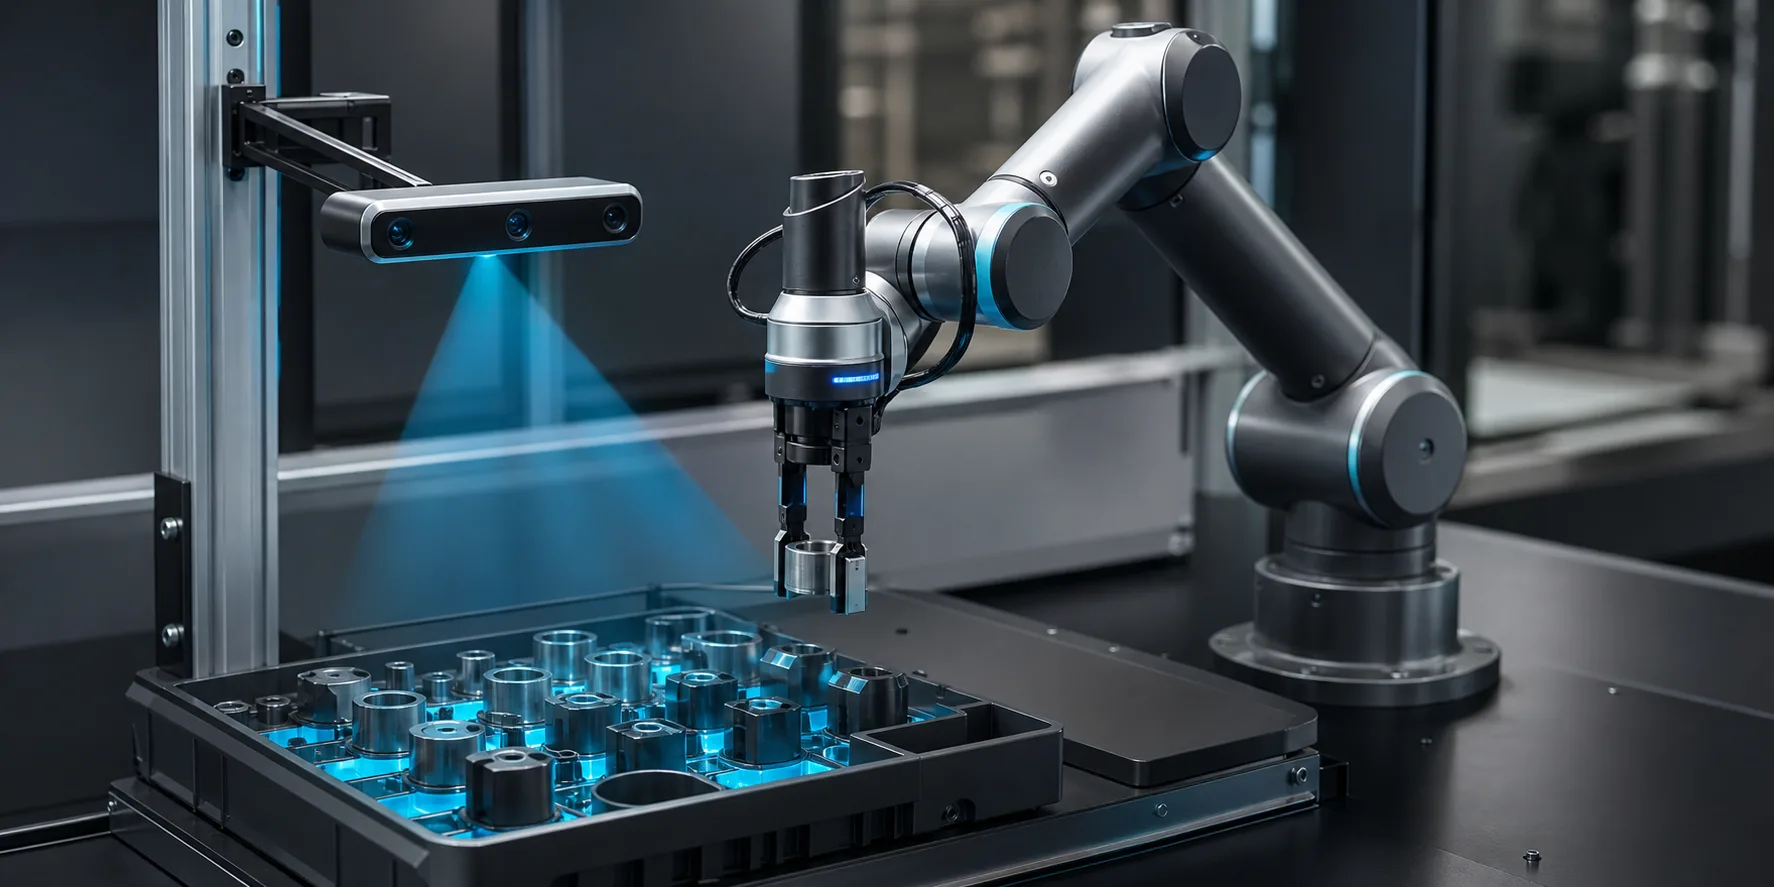
Vision-guided pick-and-place, motion planning, gripper integration and workstation safety logic.
Our public code: ROS 2 tooling used by the community, and the material behind our Physical AI workshops.
Export Fusion 360 robot designs to URDF for ROS 2. Featured in Mastering ROS 2 for Robotics Programming.
ToolBeginner-friendly GTK4 installer for ROS 2 Humble, Jazzy and Lyrical, with simulation, Nav2 and MoveIt 2 options.
ToolInstall or remove a ROS 2 distribution with a single command.
WorkshopDocker template for the Physical AI workshop at ROSCon 2025.
WorkshopBuilding intelligent robots with ROS 2: perception, planning, control and real-world deployment.
WorkshopVision-language models on TurtleBot 4, Unitree Go2, Franka and Spot in ROS 2 and Gazebo.
WorkshopAn end-to-end Physical AI workflow with the SO-101 arm, Isaac Lab and Isaac GR00T.
WorkshopHands-on tutorial project for learning NVIDIA Isaac Lab.
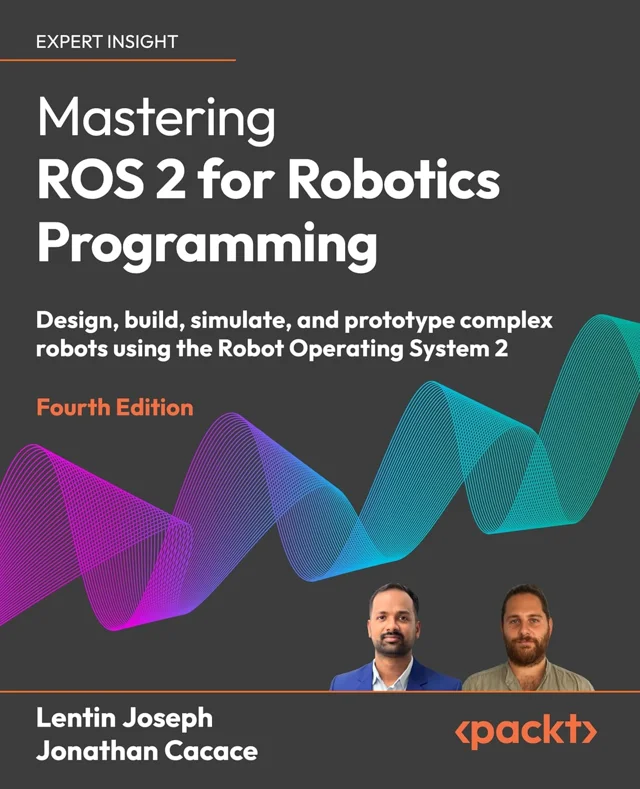
Design, build, simulate and prototype complex robots using the Robot Operating System 2.
The book features our open-source Fusion 360 → URDF exporter for ROS 2.
See all books on Amazon ↗RUNTIME Robotics works with commercial and research teams on robot software, simulation, algorithms, perception and integration, helping turn robotics ideas into reliable systems while sharing practical knowledge through training.
ROS developer and educator since 2010, author of 11 books on ROS, and a hands-on engineering partner for simulation, navigation and robot-software projects.
View LinkedIn profile
ROS software developer, educator and co-author supporting practical robot-software delivery, training and modern ROS 2 development workflows.
View LinkedIn profile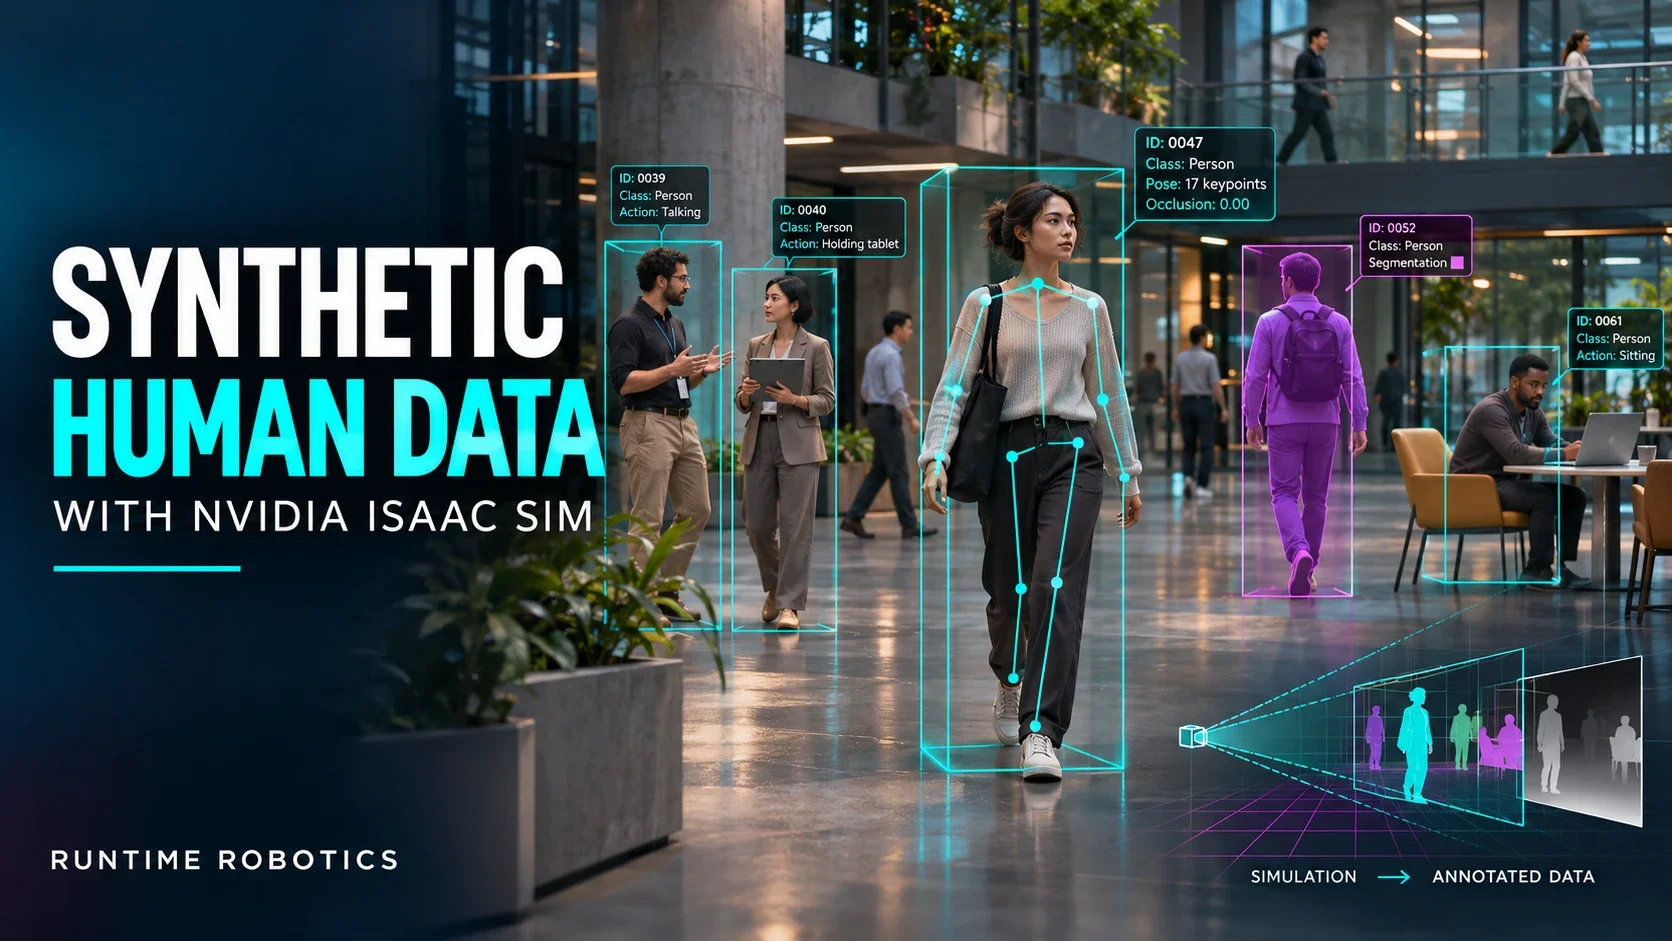
How we build diverse digital humans in Blender, convert them for Isaac Sim, animate them and generate validated pose datasets for robot perception.
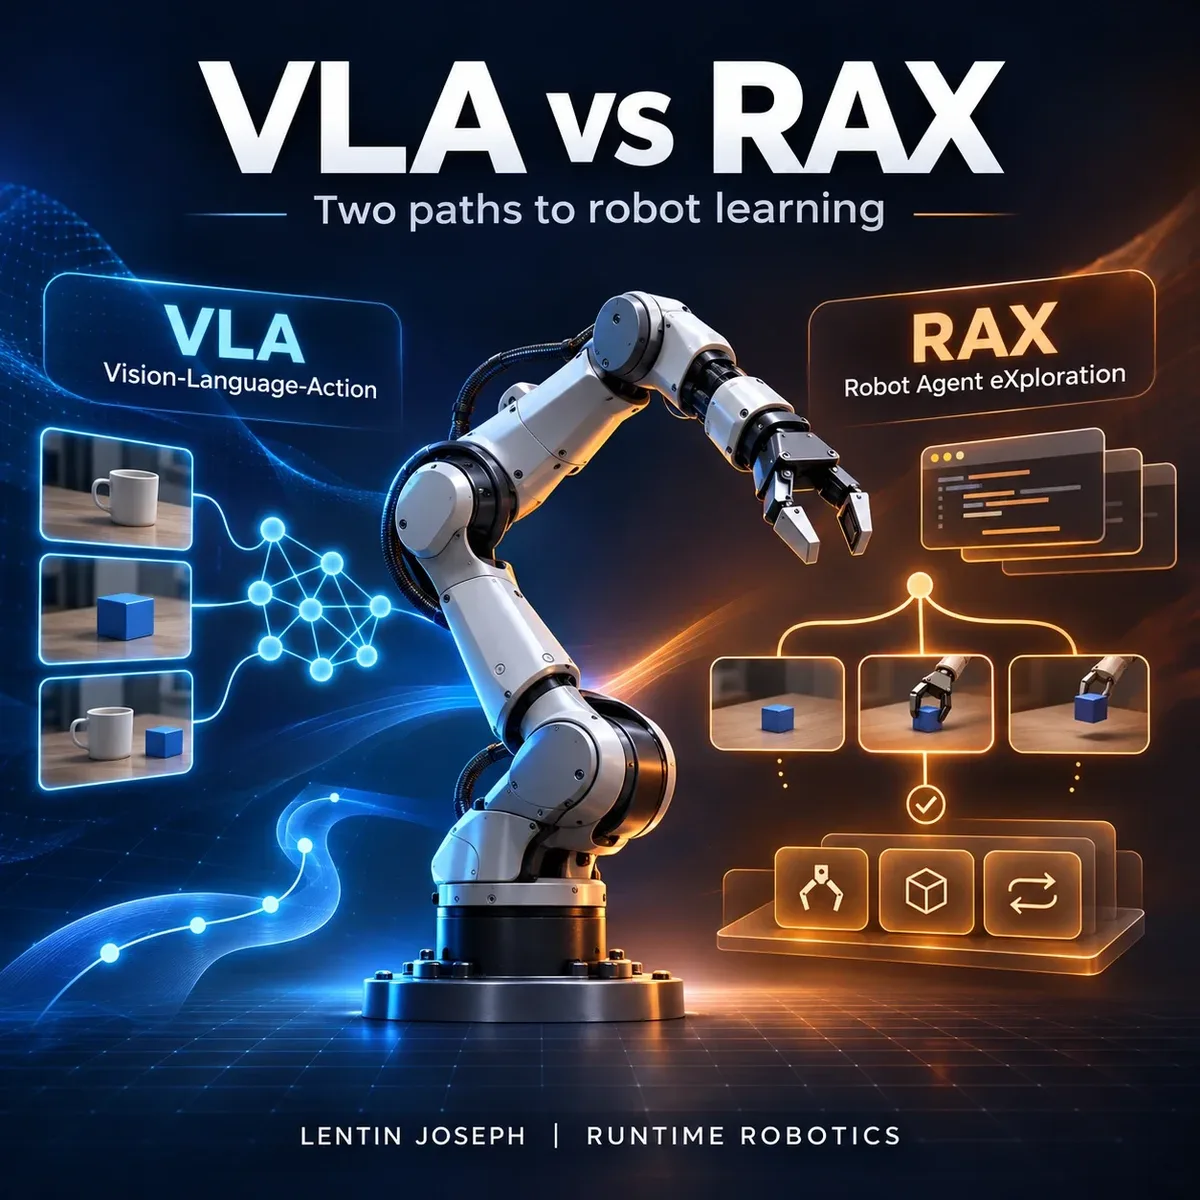
Two paths to robot learning: Vision-Language-Action models that learn from demonstrations, and RAX coding agents that explore and write their own reusable skills.
A 43-slide industry briefing on where robot foundation models are running today, where they're still in pilots, and an eight-stage playbook for taking one to production.
Tell us what robot, software stack and development challenge you are working on.