Robot perception
Perception systems that give robots usable world understanding
Develop robust perception pipelines that turn cameras, LiDAR and depth sensors into reliable scene information for navigation, inspection and manipulation.
Discuss your project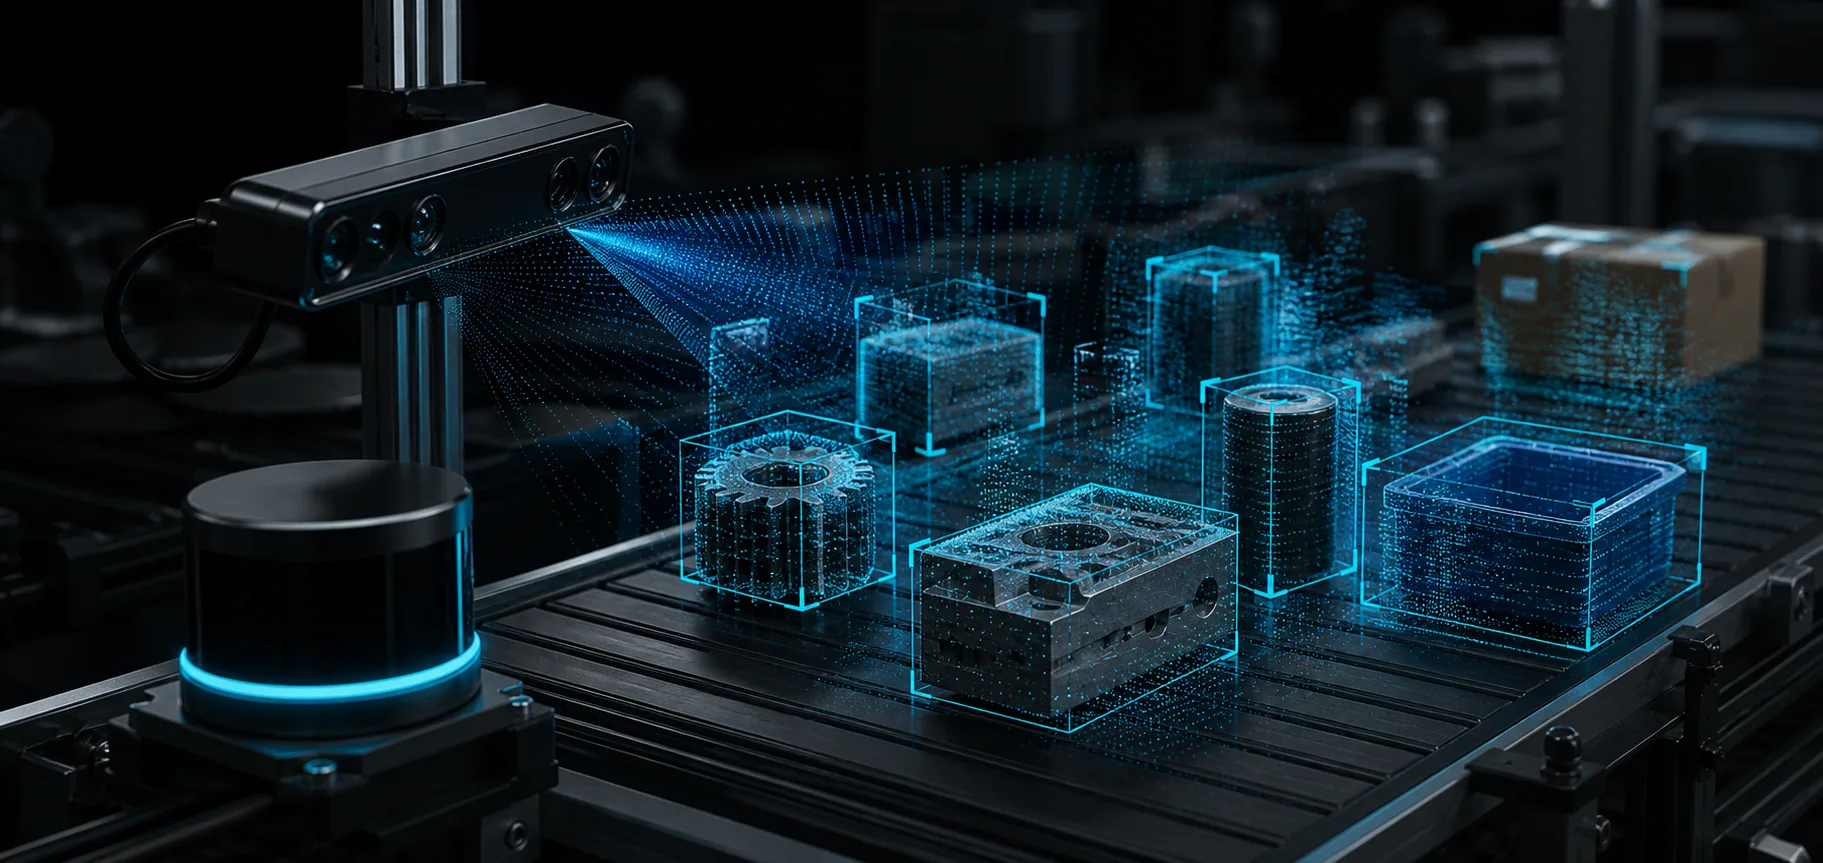
What we deliver
Engineering support tailored to your robot
- Camera, depth and LiDAR sensor integration
- Object detection, tracking and semantic understanding
- 3D perception, pose estimation and sensor fusion
- GPU-accelerated edge deployment and ROS 2 integration
Technology focus
Built with an interoperable robotics stack
How we work
From first conversation to a validated robot
- Discovery and scopingWe agree on the robot, software stack, task and measurable success criteria.
- Simulation-first prototypeWe build and test in a digital twin, such as Isaac Sim or Gazebo, before touching hardware.
- Integration on the robotWe bring it onto your hardware through clean ROS 2 interfaces, drivers and safety limits.
- Validation and handoverWe test against the agreed criteria and hand over code, documentation and team training.
FAQ
Common questions
Which sensors do you integrate?
RGB and RGB-D cameras, stereo and depth cameras such as Intel RealSense, LiDAR and IMUs, published as calibrated ROS 2 topics with correct transforms.
Can perception models run on the robot itself?
Yes. We optimise detection and tracking pipelines for edge hardware such as NVIDIA Jetson, using GPU-accelerated Isaac ROS packages where they fit.
What if we don't have enough training data?
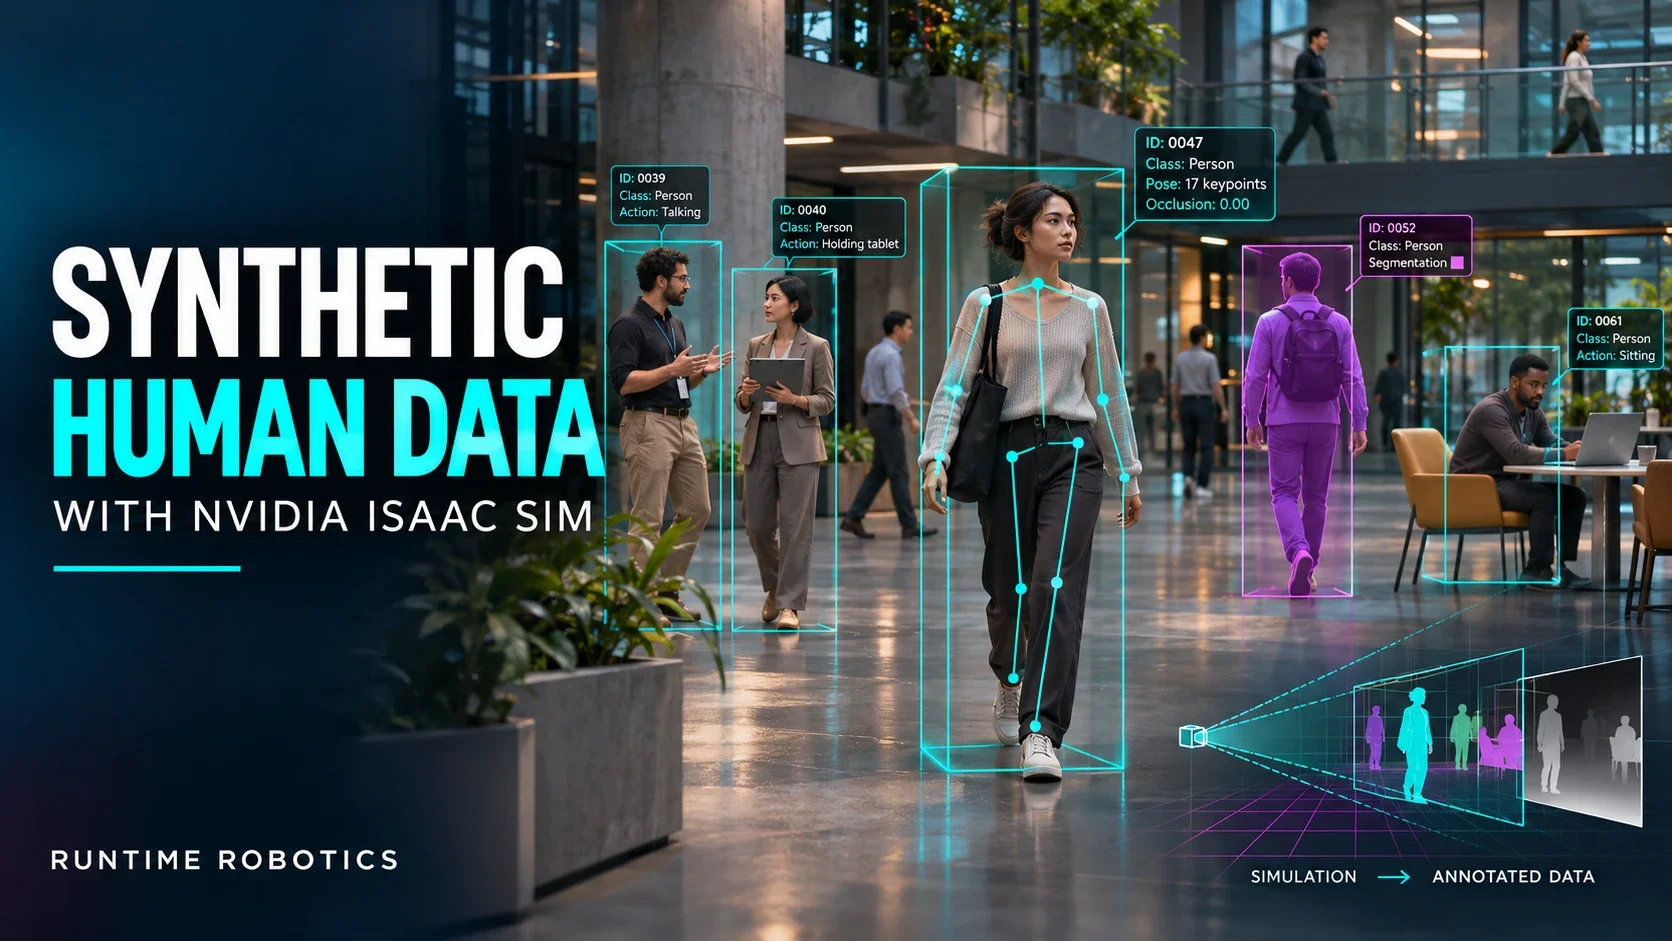
We can generate labelled synthetic data in NVIDIA Isaac Sim, such as people, objects and scenes with boxes, segmentation and keypoints, and validate it before training.
Start a conversation
Tell us about your platform, technical goal and timeline.
We can help define the engineering path from an initial prototype to a validated robot-software workflow.
Contact RUNTIME Robotics