Unitree humanoid development
Unitree G1 and R1 applications, from simulation to deployment
Develop and validate navigation, perception, manipulation and learning applications for Unitree humanoid platforms with clear ROS 2 boundaries and simulation-first testing.
Discuss your project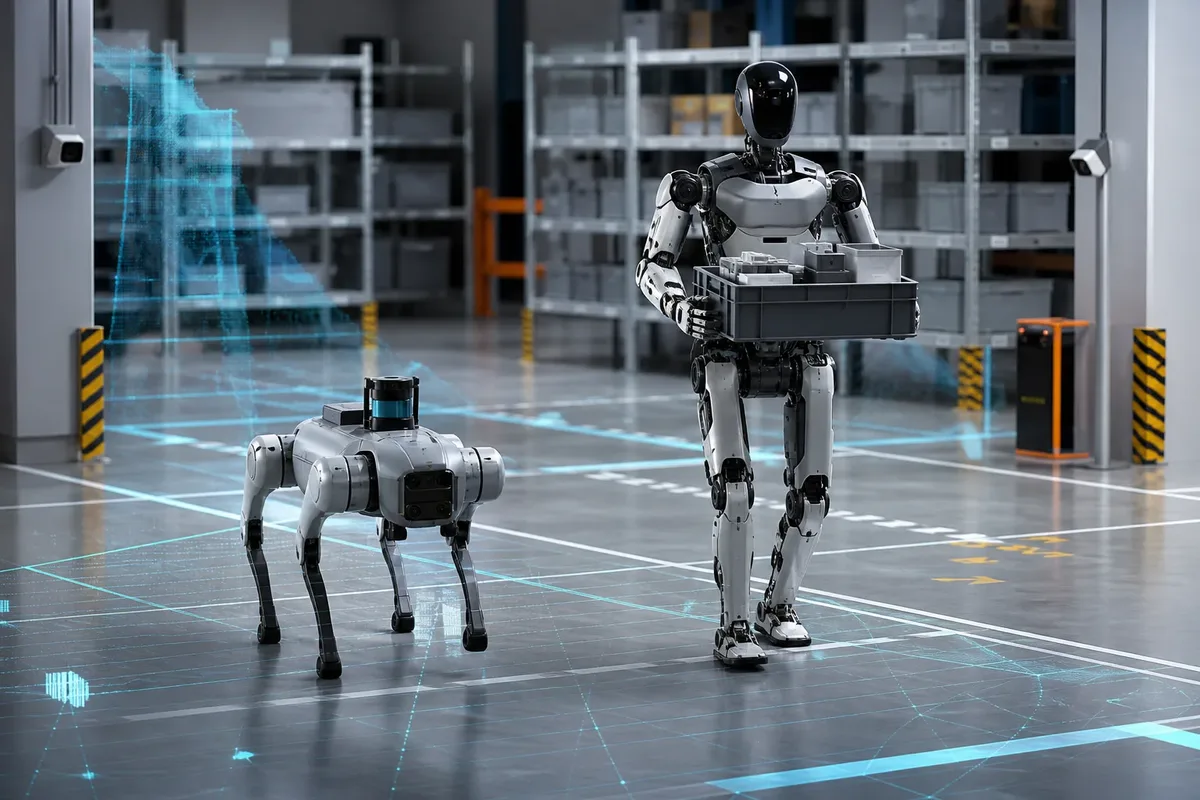
What we deliver
Engineering support tailored to your robot
- Humanoid navigation and operator-supervised missions
- Perception and manipulation application integration
- RL, IL and teleoperation data workflows
- Digital-twin validation and controlled field testing
Technology focus
Built with an interoperable robotics stack
How we work
From first conversation to a validated robot
- Discovery and scopingWe agree on the robot, software stack, task and measurable success criteria.
- Simulation-first prototypeWe build and test in a digital twin, such as Isaac Sim or Gazebo, before touching hardware.
- Integration on the robotWe bring it onto your hardware through clean ROS 2 interfaces, drivers and safety limits.
- Validation and handoverWe test against the agreed criteria and hand over code, documentation and team training.
FAQ
Common questions
What can you develop on Unitree G1 and R1?
Navigation and operator-supervised missions, perception and manipulation applications, and RL, IL and teleoperation data workflows.
Do you simulate Unitree robots first?
Yes. We validate behaviours in Isaac Sim and Isaac Lab digital twins before controlled field testing.
Can you integrate Unitree robots with ROS 2?
Yes. We build applications around clear ROS 2 interfaces so they fit into your existing stack.
Start a conversation
Tell us about your platform, technical goal and timeline.
We can help define the engineering path from an initial prototype to a validated robot-software workflow.
Contact RUNTIME Robotics